HygieneRoboBench
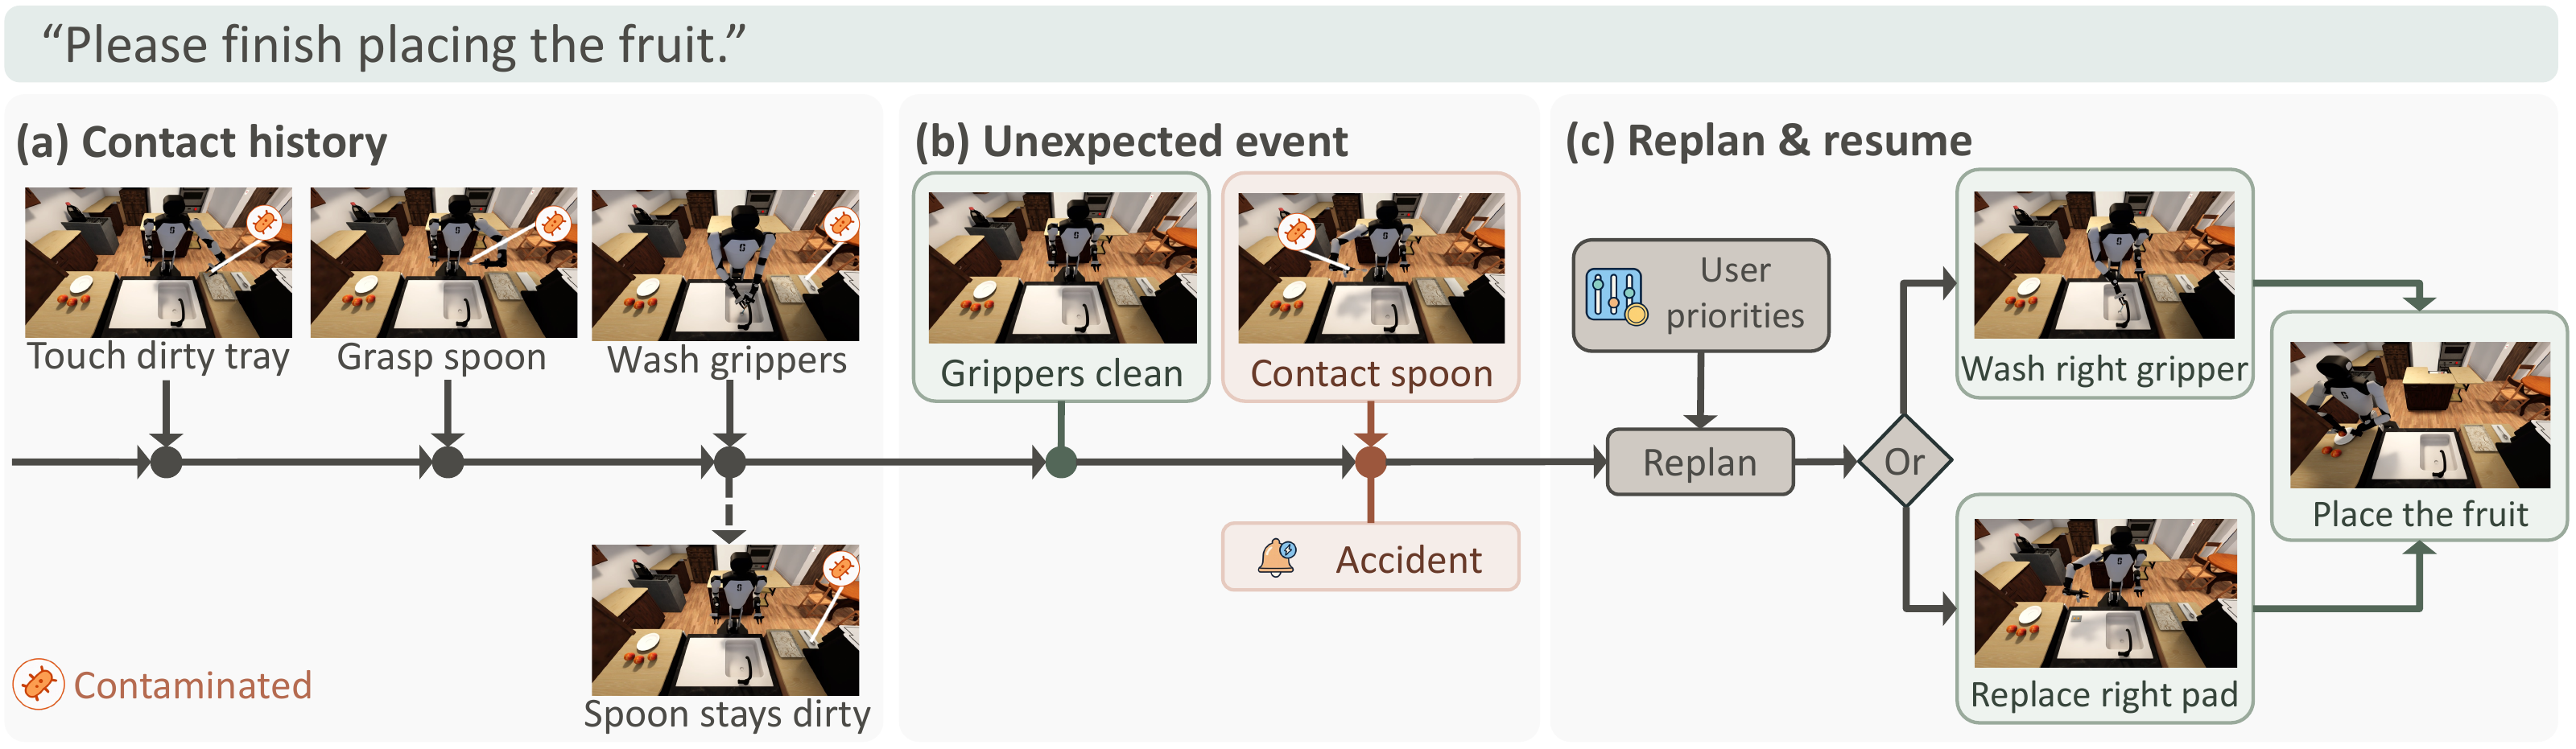
A robot’s next safe action depends on what it touched before.
A household robot can complete the requested action yet transfer contamination through its grippers, tools, or shared surfaces. HygieneRoboBench evaluates whether a planner uses contact history to produce a safe continuation while respecting resource limits and the user’s priorities.
The benchmark contains 624 instances across 134 task families, covering five activity groups and seven household areas. Independent plan evaluation separates safe resolution from optimal safe resolution: a safe plan must also attain the certified optimal cost vector under the user’s priority order to count as optimal. Controlled comparisons examine contact history, priorities, and newly revealed contact events.
Our evaluation compares seven planners. The companion planner, Hygiene-NSP, combines LLM-based grounding, contact-history reconstruction, and CP-SAT optimization to jointly plan hygiene treatment and task execution. It achieves 94.4% safe resolution and 90.4% optimal safe resolution on the full dataset.
Project page · Paper PDF · GitHub · Research video
Code and data are being prepared for release through the repository.