Yurun Chen
PhD Student in Computer Science · SJTU–EIT

Human-Centered Embodied Intelligence · Robot Self-Understanding & Reliable Action
Email · Google Scholar · GitHub · CV
I study how robots learn to recognize and model their own bodies, and how embodied agents use contact history and execution feedback to act reliably. My work spans humanoid self-representation, hygiene-aware household planning, and real-robot deployment on Unitree G1.
I am a PhD student in the joint program of Shanghai Jiao Tong University and Eastern Institute of Technology, Ningbo, advised by Prof. Wenjun Zeng and Prof. Wentao Zhu. I received my master’s degree from Tsinghua University, advised by Prof. Ruqi Huang, and my bachelor’s degree from Dalian University of Technology.
I welcome research collaborations on robot self-representation, reliable embodied agents, and humanoid motion and manipulation. Get in touch.
Research Highlights

Humanoid Self-Representation
A robot learns which visible body is its own and predicts its 3D body shape from proprioceptive–visual experience.
Validated on a 29-DoF humanoid, with applications to reaching, collision-aware planning, and motion retargeting.
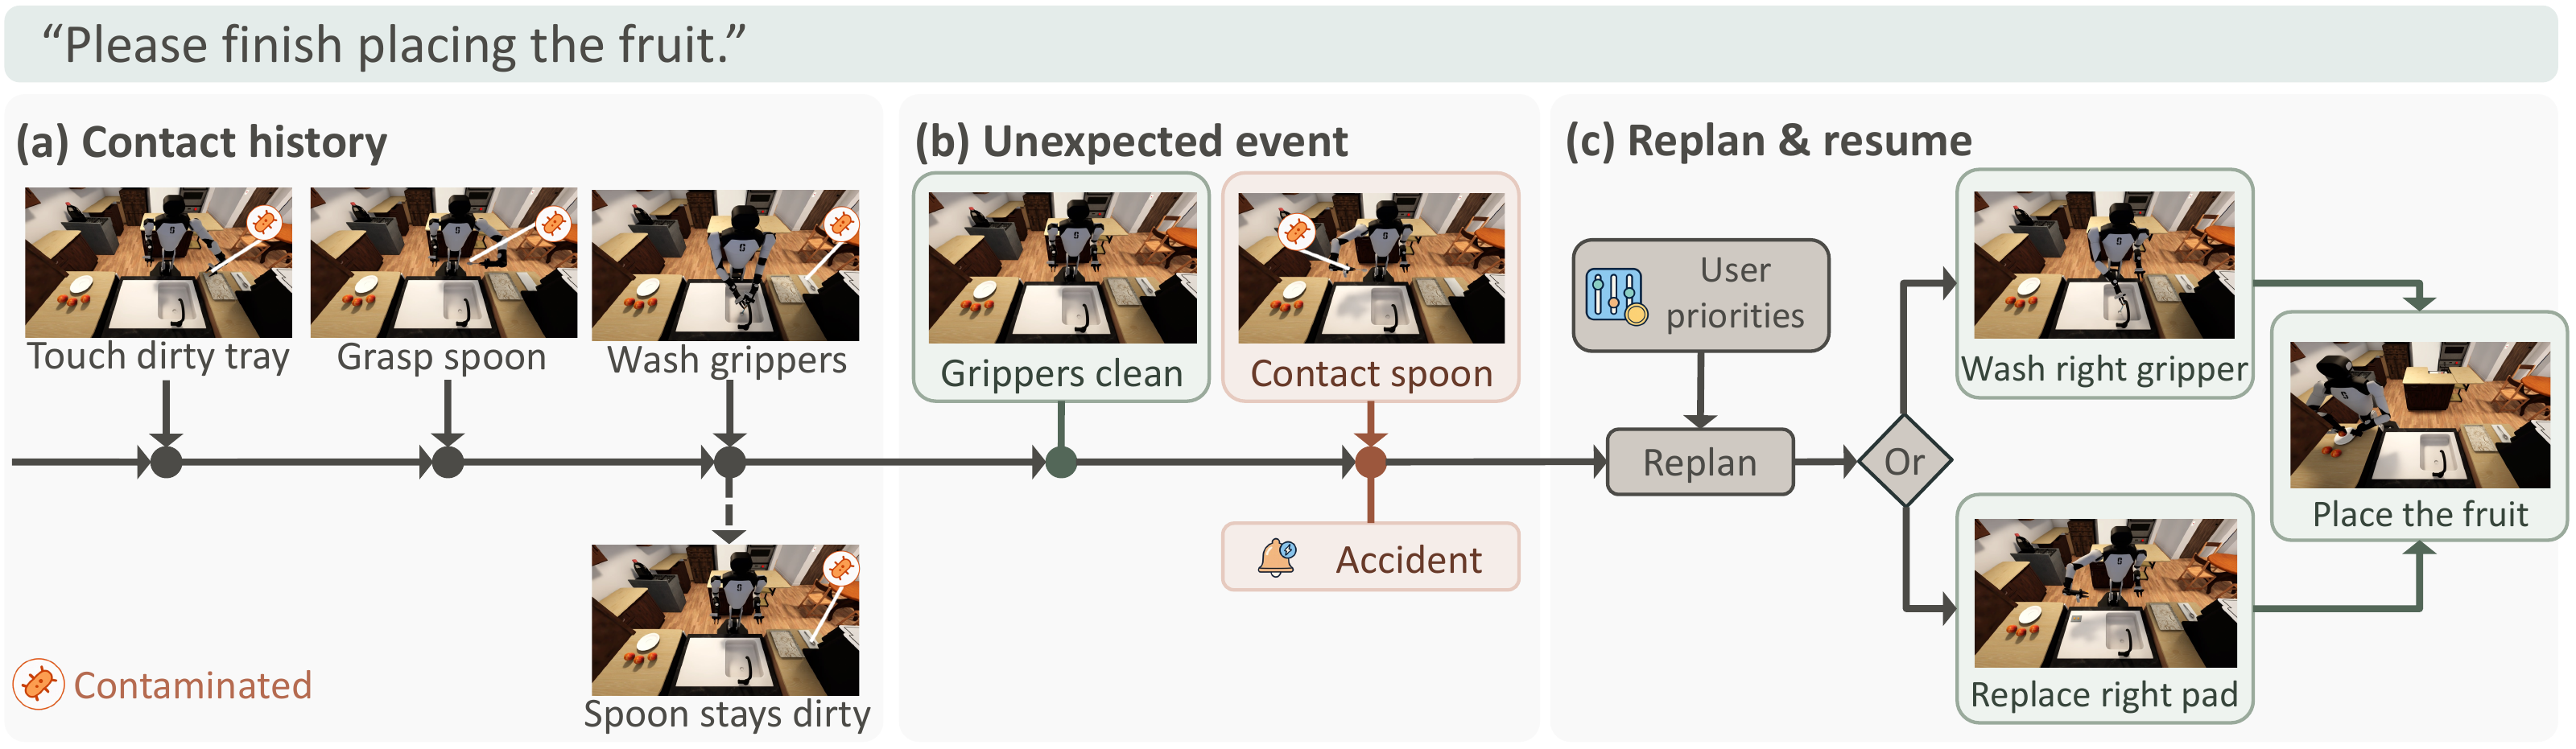
HygieneRoboBench
A robot's next safe action depends on what it touched before. We evaluate planning from contact history, user priorities, and new contact events.
624 instances · 134 task families. Hygiene-NSP achieves 94.4% safe resolution and 90.4% optimal safe resolution on the full benchmark.

Interpretable Scientific ML with KAN
JIF 12.3 (2025) · JCR Q1 (SCIE) · CAS Q1 (Top)
A radiative transfer model and a Kolmogorov–Arnold Network learn explicit soil-moisture retrieval formulas, connecting physical priors with inspectable predictions.
0.98 Pearson correlation on non-forest in-situ data, with improved interpretability and generalization over an MLP.

Thea & Unitree G1
Robot capabilities become callable tools, with persistent scene state and independent action verification for long-horizon tasks.
I led G1 locomotion, grasping, and pick-and-place deployment, and contributed to the agent loop, scene state, and outcome evaluation.
3D Vision & Geometry
My collaborative work on 3D rigging and shape correspondence includes ARMO (ICCV 2025), DRiVE (CVPR 2025), and SRIF (SIGGRAPH Asia 2024).
News
| Oct 07, 2026 | HygieneRoboBench evaluates household robot planning from contact history, user priorities, and newly revealed contact events. Our arXiv preprint, project page, and research video are available. |
|---|---|
| Aug 03, 2026 | We released the arXiv preprint Towards the Harness of Embodied Agents and the Thea project page. |
| Jun 11, 2026 | Our humanoid self–other distinction work is available on arXiv. Project |
| May 15, 2026 | Our physics-guided KAN paper on interpretable soil-moisture retrieval was published in Remote Sensing of Environment. |