Research
Selected research on human-centered embodied intelligence, humanoid self-representation, reliable embodied-agent systems, 3D vision, and interpretable scientific machine learning.
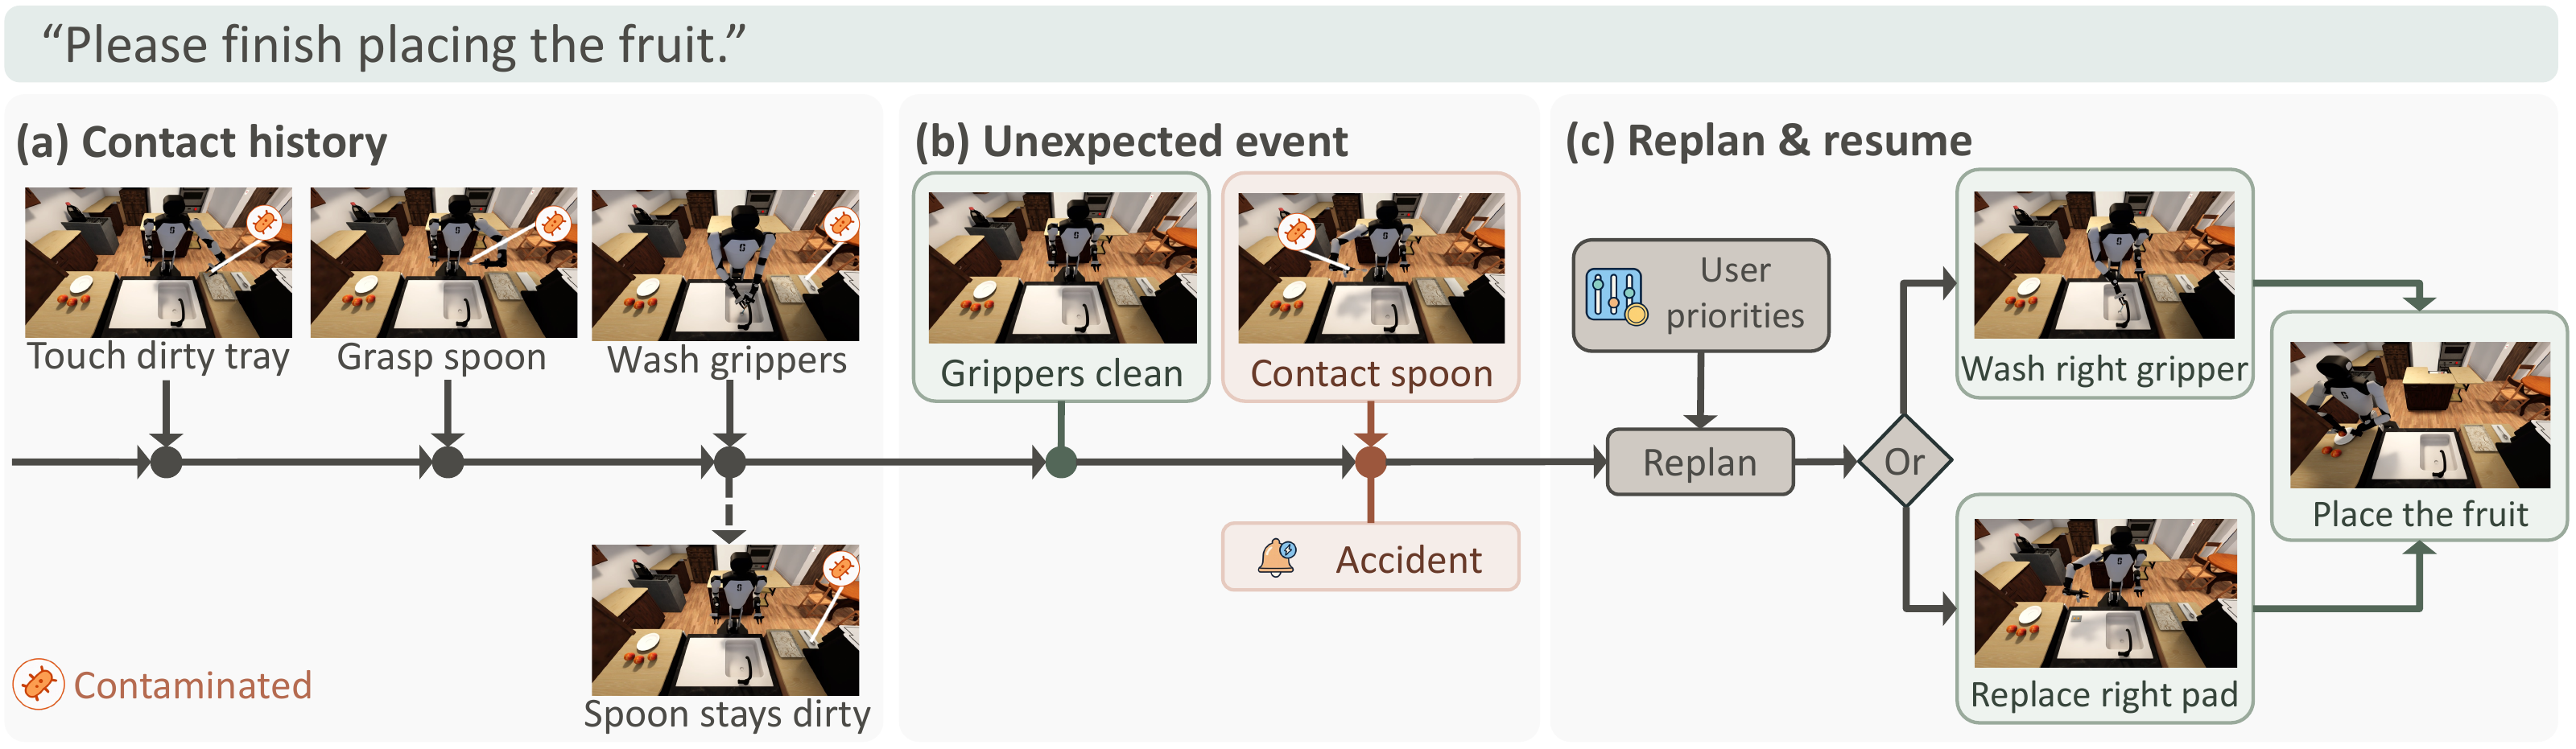
I study how robots recognize and model their own bodies, and how embodied agents use contact history and execution feedback to act reliably. My current projects explore humanoid self-representation, hygiene-aware household planning, and real-robot deployment with verified action outcomes. My broader work spans interpretable scientific machine learning and generative 3D rigging.